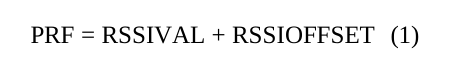Raffaele Di Bari, Qammer H. Abbasi, Akram Alomainy (2019). Cooperative Body-Worn Sensor Network for Efficient Healthcare and Activity Monitoring Applications. In: Advances in The Human Side of Service Engineering. AHFE Open Access, vol. 8. https://doi.org/10.54941/ahfe100282
Antennas and Electromagnetics Research Group, School of Electronic Engineering and Computer Science, Queen Mary University of London, Mile End Road, London E1 4NS, UK ↗
Body Sensor Networks are an interesting emerging application to improve healthcare and the quality of life monitoring. In this work, we compare the performances of multi-hop cooperative and single-hop networks with real-world sensor networks based on Zigbee technology. The network reliability, the data flow rate, the packet delivery ratio and the energy consumption are included as performances criteria. It is shown experimentally that the cooperative approach can provide a network more robust to link losses at the expenses of a lower bit rate and higher energy consumption. Specifically, for a packet delivery ratio >0.9, the cooperative scheme can provide the network with a link gain up to 14 dB traded off with an energy demand up to 30.7% higher and a data flow rate about 20% lower than a single-hop system. This work is a first exercise step in assessing reliability and life time trade-off with real-world platforms for body area sensor networks.
Research on sensor network has been carried out using small, low-power digital radios based on an IEEE 802.15 standard (IEEE, 2003), a high-level communication protocols suitable for WBANs (Otto, 2003, Jovanov, 2005). The most straightforward approach to deploy a WBAN is considering single-hop (SH) communications between sensors and the sink. However, the body impact on the signal can result in severe path losses, even larger than 50dB (Yazdandoost, 2009). Due to these high losses, direct communication between the sensors and the sink will not always be convenient (or even possible), especially when extended sensor lifetime is targeted deploying ultra-low range transceivers (Strömmer, 2007).
In a relay MH network, each sensor is dedicated to transmit or relay information packets, while in cooperative MH network each sensor can performs both operations. An example of MH WBAN benefits is introduced in (Latre, 2007), where spatial diversity gain is analyzed for a two-relay assisted transmission link, while a tree cross-layer protocols such CICADA (Braem, 2006) and WASP scheme (Su-Ho, 2010) aimed to achieve WBANs reliability and low delay, although no considerable attention is focused on balancing the power consumption between the interconnected sensors (Djenouri, 2009). Several researchers also attempted to design energy-aware MH protocols, considering also different metrics such as delay and reliability as Quality of Service requirements (Felemban, 2006, Razzaque, 2008). Although these studies shows that MH communications are suitable to overcome link blockage in sensor WBANs, the MH energy efficiency compared to the SH schemes is still an open issues and depends on several system parameters, including chipset implementation, sensors distance, and network topologies. A recent network design proposed in (Heinzelman, 2000), shown a significant increase in battery life for relay MH scenarios considering only the transmit power.
The main objective of this paper is to compare experimentally the performances of MH cooperative and SH schemes for a WBAN. The power margins, the data flow rate, the sensor packet delivery ratio (PDR) and the average energy consumption are selected as a main performance criterion. The sensors generate and transmit data at regular intervals with a data flow rate suitable for ECG constant monitoring system.
CONSIDERATIONS AND SETTING OF THE BODY-WORN SENSOR NETWORK A prototype synchronous sensor network at 2.4 GHz is set-up, where each sensor consists of a Sentilla Perk mote (Sentilla, 2008), standard compliant with the IEEE 802.15.4/Zigbee protocol. A total number of 4 sensors (with index i = 1, 2, 3 and 4) were placed on human volunteer (each attached on head, left leg, left wrist, and back) in sitting postural as shown in Fig. 1, while a sensor acting as sink is placed in the waist area. This is a representative scenario for patients who are resting for a major part of the day. The sensor 4 is placed on the volunteer’s back diametrically opposite sensor 3. The sensors are placed such that batteries are closest to skin, with the antennas being further away. With respect to the sink, two sensors are in quasi-LOS (e.g. 1 and 2) while two others are in NLOS (e.g. 3 and 4). Experiments were run in office indoor scenario.
The sink collects raw data, and sends statistics to an off-body server using a wireless link. The network operations can ideally be cyclically repeated and they can be divided in 3 main phases: (1) setting-up of the routing tree topology, (2) time-slot transmission synchronization, and (3) data transmission. A time-synchronous architecture approach was selected as best suited to maximize the data delivery ratio. The first two phases can be ranked as start- up phases, the latter as steady-state phase. The sensors send routing messages in phase 1, dummy messages in phase 2 for synchronization purposes, and actual data messages during phase 3. The network performs cycles of the 3 phases with periodicity 𝑇𝑁 to adapt its topology to the body movements and postural and environment changes.
Topology Update The Minimum Cost Forwarding (MCF) network routing protocol (Fan, 2001) has been implemented on the top of the standard connection functionality provided by the Sentilla motes kit. The routing algorithm adopted seeks to achieve minimum cost from each sensor toward the sink, where costs are proportional to the RSSI. In SH case, each sensor transmits by default to the sink so no routing data is required, while in MH protocol case, each sensor retains the next hop target sensor address to build the tree topology. From previous published works (Holland, 2006, Barsocchi, 2009), the RSSI seems to provide a good estimation of packet loss rates; e.g. RSSI of −90 dBm or larger always corresponds to a PDR of 95% or more. The RSSI register value RSSIVAL can be referred to the power PRF at the RF pins by using the following equations:
Equation reproduced from the original PDF.
where the RSSIOFFSET is approximately –45 (e.g. if reading a value of –20 from the RSSIVAL register, the PRF is approximately –65 dBm). The RSSIVAL can directly be related to the path loss 𝐿𝑃 and to the transmit power 𝑃𝑇𝑋 according
RSSIVAL = PTX - LP - RSSIOFFSET (2) As transmit and receive antenna gain cannot be explicitly estimated because of the relative orientation and body impact, they are considered as embedded in the 𝐿𝑃 term. The PRF values are not numerically suitable as link costs for the routing algorithm. In fact, the sum of any MH links combination will not be lower than the SH links, even for MH power-wise convenient routes.
Fig. 1. Displacement map of 4 sensors and a sink network on volunteer body.
Synchronisation Phase The transmit time slots are synchronised in Phase 2 using beacons with a unique sensor address periodically sent by the sink. In this phase, each sensor is constantly in receiving mode, listening for sink beacons and other sensor massages. If a beacon is received, the sensor set up a wake-up timer and send a packet to the next hop target sensor (or to the sink in case of SH scheme). If a sensor receives a message, it simply relays to the next hop. Thus, the sink and the sensors involved in relaying can synchronize their wake-up timers for receiving the messages from neighbourhood sensors. As the sink knows the total number of sensors (but not the network topology nor the latency a priori), it does not send a new beacon until a packet is received from the target sensor. As the massage delay depends of number of hops, R is expected to lower in MH scheme. After phase 2, the sink and the sensor have set a wake-up time, and no beacons are required anymore.
Transmission Phase At the end of phase 2, the communication between sensors is time-slotted according the wake up times to avoid idle listening and save energy. Each sensor regularly transmits data packets of 75 bytes of payload. In case of MH protocol, a sensor relays messages from neighbourhood sensors immediately after reception, with no data buffering. The sensor operation type (e.g. transmit or transmit and relay) depends on the network topology and it can dynamically change every cycle 𝑇𝑁. Considering a sensor in transmit operation type as shown in Fig. 2, the communication tasks are divided into 3 time slots: in 𝑇𝑃, the sensor generate data to transmit, in 𝑇𝑇𝑋 the sensor transmit the data packets, while in TS the sensor is in sleeping mode. 𝑇𝑇𝑋 is fixed and empirically estimated to be ~108ms. This value includes value data serialization, a method of transforming Java objects into a byte stream (binary form), so they can be sent and received over the radio. Thus, the actual time required to transmit data itself is <100 ms. The sensor sleeping time is TS and it varies according the synchronisations, while the active time is defined as TA=TTX+TP, where TP is ~72ms.
DATA PROCESSING AND ANALYSIS This section presents the results of the real-world tests. Considering a static posture of the patient, we assume a Human Side of Service Engineering (2019) constant time average for RSSI is assumed per each link. Each body link has been preliminary characterized in terms of measured average RSSI; data are stored in the devices memory and associated to each link before the experiments. As the links costs are now fixed, a single network cycle TN is enough for each test. This approach has the benefits of comparing the SH and MH energy consumptions for the same network topology, enabling a separate study of the packet losses due to the synchronization drifts from those due to the PRF dropping below the sensitivity threshold, and the repeatability of the results.
Fig. 2. Packet data communication tasks for a (A) transmit sensor, (B) relay sensor and Sink sensors operation modes (blocks are not in scale)
Network topologies and body links characterization A preliminary characterization of the network topology in terms of link cost and time variability is performed. Per each link (e.g. [Equation or mathematical symbol available in the original paper PDF]13), a data packet was sent every 1 second at 0 dBm of transmit power, for an observation time of 2 minutes. Each measurement was repeated 3 times and data were merged in a single history vector for each link. Per each packet, a RSSI measurement based on the Zigbee standard was stored and the path losses statistics are derived these values. While taking measurements, the volunteer was allowed to perform changes in the posture, as naturally happens in such scenario.
In case of MH scheme, the routing protocol sets the sensor 1, 2 and 4 to communicate directly to the sink, as these links have a lower link cost if compared with any other MH link combination. The sensor 3 transmits to the sensor 4 and the latter acts as relay. In fact, considering the RSSI, the [Equation or mathematical symbol available in the original paper PDF]S3 link cost (where S stands for sink) is higher than the sum of [Equation or mathematical symbol available in the original paper PDF]13 and [Equation or mathematical symbol available in the original paper PDF]4S link costs (e.g. (-16)+(-9)<-30). This can potentially results in transmit a power margin for the sensor 3 of 14 dB if compared to the SH case. The PRF values are not numerically suitable as link costs for the routing algorithm. In fact, the sum of any MH links combination will not be lower than the SH links, even for MH power-wise convenient routes. As discussed before, only the 4 links relative to the sink are of interest for both SH and MH, while [Equation or mathematical symbol available in the original paper PDF]34 is of interest for MH only. The LS time histories of these links are shown in Fig. 3, while Table 1 shows the statistical parameters. The standard variation σ spans from 5 dB to 8.1 dB, while the power range is up to 66 dB.
Network packet delivery ratio (PRR) and data flow rate performances From Table 1, the sensor 3 has M0 of 20 and 34 dB for the SH and MH case, respectively. Moreover, [Equation or mathematical symbol available in the original paper PDF] is 8.1 and 5.0 dB for the [Equation or mathematical symbol available in the original paper PDF]S3 and [Equation or mathematical symbol available in the original paper PDF]34 cases, respectively. The probability of exceeding M0 (or link blockage probability) is about 7·10-3 for the SH and about 5·10-12 for the MH case. Thus, a [Equation or mathematical symbol available in the original paper PDF]S3 blockage is significantly more likely than a [Equation or mathematical symbol available in the original paper PDF]34 link blockage. Figure 4 shows the SH PRR (primary y-axis on the right) and r (secondary y-axis on the left) for [Equation or mathematical symbol available in the original paper PDF]S3 with and without link blockage. The results are compared with the MH PRR and r with no link blockage on the [Equation or mathematical symbol available in the original paper PDF]34 link. The cases for Tw = 93.75 and 250 ms are considered. The PRR is > 0.9 for both SH and MH schemes with no links blockage. In case of MH network, it is shown the capability of sensor 4 to receive and route to the sink at least the data from the sensor 3 with a PRR comparable (e.g. PRR > 0.9) to the SH case with no blockage. In case of [Equation or mathematical symbol available in the original paper PDF]S3 link blockage, the SH PRR degrades of about 23% compared to the MH with no link blockage for both Tw cases, while the SH r reduction is 21% and 25% for the Tw case of 93.75 ms and 250 ms, respectively. This means that the MH topology can be used to overcome SH link blockages theoretically without PRR degradation, as the MH lower r compared to SH scheme is merely due to the synchronization basic approach discussed beforehand and it will be
deepened later in this section. As mentioned in Section II, the PRR (and consequently r) depends directly on the waiting time (TW) value. For this reason, both the PRR and r are preliminary studied against the TW to maximize the data r while keeping at minimum the packet losses.
Fig. 3. Sample LS history during the first 100 measurement seconds with sampling rate of 1 second.
Table 1. Average path loss, available margins and statistical parameters of LS per each link of interest
Table available in the original PDF paper.
LS [dB] Link LAVG [dB] M0[dB] [Equation or mathematical symbol available in the original paper PDF] Range Min. Max.
As path loss LS can change significantly in time even for sitting postural because of body movements, it is important to compare M against the energy consumption. The relationship between the transmit power and the sensor current consumption is not linear. The energy consumption can be estimated as a function of data packets transmitted, based on the exact circuitry being used. As a 1.8V chipset voltage is used and the defined bit rate is 250 Kbps (Fan, 2001), Ẽrx is 135.4 nJ/bit, while Ẽtx at PT = 0 dBm is 125.28 nJ/bit. The microcontroller energy costs are not considered. From (Fan, 2001), the current consumption in idle and sleep modes are significantly smaller (>500µA) compared to the maximum transmit and receive currents (17.7 and 18.8mA, respectively) and they are not considered neither.
The energy consumptions estimation only represents the energy per bit dissipated in the transceiver. As the extra energy dissipated during overhead processing (data generation, data serializations, etc.) and the media access control (MAC) related (such as the waiting time TW) are not considered, this approach provides more general results as the energy is approximate using only the network topology, the transmitted power, the chipset implementation, the bitrates and the target reliability.
CONCLUSIONS
In this paper the potential benefits and limitations of cooperative networks as a means of augment the reliability in body-wearable sensor are studied. These trade-offs have been quantified for a sensor network prototyping a real- world platform for continuous ECG healthcare monitoring. For a packet delivery ratio >0.9, the MH scheme can provide the network with a margin gain up to 14 dB traded off with an energy demand up to 30.7% higher and an average sensors r 20% lower than a SH scheme. The network lifetime of the MH scheme ranges from the 27% to 45% of the SH lifetime in cases of 0 dB and 20 dB margins, respectively. This work is a first exercise step in assessing reliability and life time trade-off with real-world platforms for body area sensor networks. Follow-up studies will address wireless ECG emulators with higher number of sensors (e.g. up to 10 for a typical 12-leads ECG system) employing ultra-low power chipsets in different specific health monitoring environments, such as critical care in hospitals, aged care or athlete monitoring.
Fig. 4. Total Packet Delivery and throughput r for the SH and MH cases.
REFERENCES
Barsocchi, P., Oligeri, G., Potortì, F. (2009), “Measurement-based frame error model for simulating outdoor Wi-Fi networks”, IEEE Transactions on Wireless Communications, Vol. 8, No. 3, March 2009, pp. 1154-1158. Braem, B., Latré, B., Benoît, M., Blondia, C., Demeester, P. (2006), “The wireless autonomous spanning tree protocol for multi-
hop wireless body area networks,” presented at 2006 3rd Annual International Conference on Mobile and Ubiquitous Systems, San Jose, CA. Djenouri, D., Balasingham, I. (2009), “New QoS and Geographical Routing in Wireless Biomedical Sensor Networks,” in Proc.
of the 6th Int. Conf. on Broadband Communications, Networks, and Systems, Madrid (Spain), 2009, pp. 1-8. Fan, Y., Songwu, L., Lixia, Z. (2001), "A Scalable Solution to Minimum Cost Forwarding in Large Sensor Networks", in Proc.
of 10th Int. Conf. Comp. Communications and Networks, 2001, 304–309. Felemban, E., Lee, C. G., Ekici, E. (2006), “MMSPEED: Multipath multi-speed protocol for QoS guarantee of reliability and timeliness in wireless sensor networks,” IEEE Transaction on Mobile Computing, Vol. 5, No. 6, pp. 738-754, 2006. Heinzelman, W. R., Chandrakasan, A., Balakrishnan, H. (2000), "Energy-efficient communication protocol for wireless
microsensor networks," in Proc. of the 33rd Annual Hawaii Int. Conf. on System Sciences, 2000, pp. 10 pp. vol.2, 4-7. Holland, M. M., Aures, R. G., Heinzelman, W. B. (2006), "Experimental investigation of radio performance in wireless sensor networks," presented at 2nd IEEE Workshop on Wireless Mesh Networks, 2006, pp.140-150. IEEE std. 802.15.4 - 2003: Wireless Medium Access Control (MAC) and Physical Layer (PHY) Jovanov, E., Milenkovic, A., Otto, C., De Groen, P. C. (2005), “A wireless body area network of intelligent motion sensors for
computer assisted physical rehabilitation,” Journal of NeuroEngineering and Rehabilitation, 2:6, March 2005. Latre, B., Braem, B., Moerman, I., Blondia, C., Reusens, E., Joseph, W., Demeester, P. (2007), “A low-delay protocol for multihop wireless body area networks,” in Proc.of 4th Int. Conf., MobiQuitous, pp. 1-8, 2007. Otto, C., Milenkovic, A., Sanders, C., Jovanov, E. (2006), “System Architecture of a Wireless Body Area Sensor Network for
Ubiquitous Health Monitoring,” Journal of Mobile Multimedia, Vol. 1, No. 4, 2006, pp. 307-326. Razzaque, A., Alam, M. M., Or-Rashid, M., Hong, C. S. (2008), “Multi-constrained QoS geographic routing for heterogeneous traffic in sensor networks,” IEICE Trans. on Communications, Vol. 9lB, No. 8, pp. 2589-2601, 2008. Sentilla Wireless Sensor Development Kit. Available at: http://www.sentilla.com/blogs/2008/05/sentilla-announces-worlds-
smal.php Human Side of Service Engineering (2019)
Strömmer, E., Hillukkala, M., Ylisaukkooja, A. (2007), “Ultra-low Power Sensors with Near Field Communication for Mobile Applications,” presented at 2007 Int. Conf. On Wireless Network, Las Vegas, Nevada. Su-Ho, S., Gopalan, S.A., Seung-Man, C., Ki-Jung, S., Jae-Wook, N., Jong-Tae Park, P. (2010), “An energy -efficient
configuration management for multi-hop wireless body area networks,” in 3rd IEEE Int. Conf. on Broadband Network and Multimedia Technology, pp. 1235 – 1239, 2010. Yazdandoost, K. Y., et al. (2009), “Channel models for body area network,” IEEE P802.15-08-0780-08-0006, Apr. 2009.
LISTED IN THE AHFE DIGITAL BOOKSTORE CATALOGUE
Explore the complete digital volume
Advances in The Human Side of Service Engineering
Read this individual research paper free through the original publisher, or explore the full digital proceedings book.
ISBN 978-1-4951-2091-6
Explore this ISBN in the AHFE Bookstore ↗Listed in the July 2026 bookstore catalogue; search by ISBN to confirm current availability · Digital book purchase optional