Jooyoung Park, Taewon Yang, Jonghyun Kim, Ronald Boring, Chad Pope (2023). An Investigation of Time Distributions for Task Primitives to Support the HUNTER Dynamic Human Reliability Analysis. In: Emerging Technologies and Future of Work. AHFE Open Access, vol. 117, pp. 21–28. https://doi.org/10.54941/ahfe1004401
As an effort to support data collection for dynamic human reliability analysis (HRA), this study investigates time distributions for task primitives defined in the Goals, Operators, Methods, and Selection rules (GOMS)–Human Reliability Analysis (HRA) method. GOMS-HRA was developed to provide cognition-based time and human error probability information for dynamic HRA calculation in the Human Unimodel for Nuclear Technology to Enhance Reliability (HUNTER) framework. HUNTER is a framework to support the dynamic modelling of human error in conjunction with other modelling tools. In this paper, we investigate time distributions using experimental data collected from the Simplified Human Error Experimental Program (SHEEP) study, which suggests an HRA data collection framework to complement full-scope simulator research as well as collect input data for dynamic HRA using simplified simulators such as the Rancor Microworld Simulator. In this study, time required for GOMS-HRA task primitives to satisfy thirteen statistical distributions is investigated. Then, the time distributions from student operators and professional operators are compared and discussed. As a result, this study identified several time distributions on five GOMS-HRA task primitives at a statistically significant level. According to analyses to date, a greater number of significant time distributions was found in abnormal or emergency operating procedures rather than standard operating procedures. In the future, it is expected that the result of this study can provide objective reference on elapsed time data for task primitives as well as help to realistically simulate scenarios within dynamic HRA.
Human reliability analysis (HRA) is an approach to evaluate human errors and quantify human error probabilities (HEPs) for application in probabilis- tic risk assessment (PRA) (Swain & Guttmann, 1983). The Risk-Informed System Analysis (RISA) pathway under the U.S. Department of Energy’s Light Water Reactor Sustainability (LWRS) Program sponsors a number of
HRA-related projects that aim to create better tools to support industry risk assessment needs. One such tool is the Human Unimodel for Nuclear Technology to Enhance Reliability (HUNTER) project (Boring, et al., 2022). HUNTER is a framework to support the dynamic modeling of human error in conjunction with other modeling tools. HUNTER creates a virtual opera- tor or, potentially, a human digital twin as a human operations counterpart to plant hardware modeling and simulation. The name HUNTER is meant as a counterpart to the various animal-named modeling tools developed at Idaho National Laboratory (INL), such as Risk Analysis Virtual Code ENvironment (RAVEN) and Multiphysics Object-Oriented Simulation Envi- ronment (MOOSE). These tool names playfully combine to become tools like RAVEN-HUNTER or MOOSE-HUNTER.
Our research team has developed an HRA data collection framework called the Simplified Human Error Experimental Program (SHEEP) to com- plement full-scope simulator studies as well as collect input data for dynamic HRA like HUNTER (Park, et al., 2022). The SHEEP framework aims to infer full-scope data based on experimental data collected from simplified simulators, specifically the Rancor Microworld Simulator (Rancor) and the Compact Nuclear Simulator (CNS). Within the SHEEP framework, our research team has experimentally collected the human reliability data from forty student operators and forty professional operators when they used CNS and Rancor. To date, human errors and performance measurements collected from experiments have been analyzed and discussed in the previous research (Park, et al., 2022; Park, et al., 2023).
From within the umbrella of the SHEEP framework, this study aims to investigate time distributions for task primitives defined in the Goals, Operators, Methods, and Selection rules (GOMS)-HRA method (Boring & Rasmussen, 2016). GOMS-HRA was developed to provide cognition-based time and HEP information for dynamic HRA calculation in the HUNTER framework. In this study, we investigated time distributions for GOMS- HRA task primitives using the SHEEP database, which includes experimental data when twenty student operators and twenty professional operators using Rancor. From the experimental data, time required for GOMS-HRA task primitives to satisfy thirteen statistical distributions was investigated. Then, the time distributions from student operators and professional operators are compared and discussed.
GOMS-HRA TASK PRIMITIVES GOMS-HRA was developed to provide cognition-based time and HEP infor- mation for dynamic HRA calculation in the HUNTER framework. GOMS- HRA has been used to model proceduralized activities and evaluate user interactions with human-computer interfaces in human factors research. As a predictive method, GOMS-HRA is well-equipped to simulate human actions under specific circumstances in a scenario. The basic approach of GOMS- HRA consists of three steps: (1) breaking human actions into a series of task-level primitives, (2) allocating time and error values to each task-level primitive, then (3) predicting human actions or task durations.
An Investigation of Time Distributions for Task Primitives 23
Table 1 shows the GOMS-HRA task primitives. GOMS-HRA originally suggested twelve task primitives performed in control rooms and in the field. However, in this study, we only concentrate on the five task primitives (i.e., AC, CC, RC, SC, and DP) highlighted as grey color in the table. Actually, the SHEEP expertiment has focused on control room data when a single operator runs a simulator using procedures. Accordingly, task primitives regarding field operations (i.e., AF, CF, RF, and SF), actions regarding decision-making without procedures (i.e., DW), and communication between operators (i.e., IP, and IR) were excluded in this study.
Table 1. GOMS-HRA task primitives.
Table available in the original PDF paper.
Task Primitives Description AC Performing required physical actions on the control boards AF Performing required physical actions in the field CC Looking for required information on the control boards CF Looking for required information in the field RC Obtaining required information on the control boards RF Obtaining required information in the field IP Producing verbal or written instructions IR Receiving verbal or written instructions SC Selecting or setting a value on the control boards SF Selecting or setting a value in the field DP Making a decision based on procedures DW Making a decision without available procedures
THE SHEEP EXPERIMENT DATA The SHEEP data have been collected from twenty student operators and twenty professional operators when they used Rancor. Most of the pro- fessional operators were licensed reactor operators currently employed at nuclear power plants (NPPs). They were all operators on shift (i.e., a shift supervisor, shift technical advisor, reactor operator, or turbine operator) or instructors at the training center. As for the student operators, they were all undergraduate seniors or graduate students from the Department of Nuclear Engineering at Chosun University. They were knowledgeable about NPP systems and operations, having completed a significant por- tion of their coursework, which included courses such as “Introduction to Nuclear Engineering,”“Reactor Theory,”“Reactor Control,”and “Simulator Operation.”
This study investigated time distributions of the GOMS-HRA task prim- itives depending on procedures. Basically, procedures used in NPPs have different goals. For example, operating procedures (OP) aim to stably reach different operating modes such as startup or hot standby, while emer- gency operating procedures (EOPs) are mainly composed of instructions for rapidly cooling down reactors. Accordingly, this study distinguished seven different procedure sets as shown in Table 2. For OP-03 and OP-04, and OP-05 and OP-06, these are combined as a procedure set respec- tively because these are used in a scenario for achieving a goal. Specifically, OP-04 and OP-06 are parts of OP-03 and OP-05. In this paper, the result
of time distribution analysis on EOP-01 is mainly introduced in the next session.
Table 2. Procedure information used in the SHEEP experiment.
Table available in the original PDF paper.
Description Related Scenario
Procedure Set No.
Procedures Included
Scenario #1 (fully auto start-up)
1 OP-01 This procedure describes how to start up and operate Rancor in auto mode.
Scenario #2 (shutdown)
2 OP-02 This procedure describes the process to shut-down Rancor.
3 OP-03 & OP-04
Scenario #3 (manual rod control during start-up)
This procedure describes how to start up and operate Rancor in control rod manual operation mode.
4 OP-05 & OP-06
Scenario #4 (manual feedwater flow control during start-up)
This procedure describes how to start up and operate Rancor in feedwater manual operation mode.
5 AOP-01 This procedure shuts down the plant in an expedient manner.
Scenario #9 (steam generator tube rupture)
Scenario #5∼#10 (failure of a reactor coolant pump, failure of a control rod, failure of a feedwater pump, turbine failure, steam generator tube rupture, and loss of feedwater) 6 EOP-01 This procedure provides actions to minimize leakage of reactor coolant into the secondary system following a steam generator tube rupture.
Scenario #10 (loss of feedwater)
7 EOP-02 This procedure provides actions to diagnose and mitigate a loss of feedwater.
TIME DISTRIBUTION ANALYSIS RESULT: EOP-01 Tables 3 and 4 show the number of tasks used for time distribution analysis and the result of goodness-of-fit test for thirteen statistical distributions on elapsed time of the five GOMS-HRA task primitives in the EOP-01 proce- dure depending on participant type, i.e., student operators, and professional operators. There were 490 total tasks counted when twenty student operators and twenty professional operators manipulate Rancor using the EOP-01 pro- cedure. The number of tasks for student operators (248) was slightly higher than for professional operators (242). The differences on the number of tasks per participant type rely on cases that a participant additionally performs instructions that can be omitted within a procedure context, or a participant cannot continue a scenario because the reactor has abnormally tripped during the scenario.
Table 3. The number of tasks used for time distribution analysis (EOP-01).
Table available in the original PDF paper.
Participant Type GOMS-HRA Task Primitive The Number of Tasks per Participant Type
The Total Number of Tasks AC CC RC SC DP Student operators 59 80 49 10 50 248 490 Professional operators 57 78 49 10 48 242
An Investigation of Time Distributions for Task Primitives 25
Table 4. Time distribution analysis on the five GOMS-HRA task primitives in the EOP-01 procedure depending on participant type (student vs. operator).
Table available in the original PDF paper.
Distribution P-value of Goodness of Fit Test Student Operator
AC CC RC SC DP AC CC RC SC DP 0.374 <0.005 0.010 0.653 0.070 0.340 <0.005 <0.005 0.237 0.041 Normal <0.005 <0.005 <0.005 0.014 <0.005 <0.005 <0.005 <0.005 0.237 <0.005 Normal (after Box-Cox transformation)
Among student operators’ task primitives, elapsed time for AC was sta- tistically significant on normal distribution after Box-Cox transformation, lognormal distribution, 2-parameter exponential distribution, loglogistic dis- tribution, and normal distribution after Johnson transformation. The statisti- cal significance for elapsed time means that the data set are distributed within confidence intervals in each statistical distribution. For elapsed time for SC, the task primitive satisfied statistical significance level on normal distribution after Box-Cox transformation, lognormal distribution, exponential distribu- tion, 2-parameter exponential distribution, Weibull distribution, 3-parameter Weibull distribution, gamma distribution, loglogistic distribution, and nor- mal distribution after Johnson transformation. In addition, elapsed time for DP was statistically significant on normal distribution after Box-Cox transformation, lognormal distribution, and exponential distribution. On the other hand, elapsed time for AC from professional operators’ data showed statistically significant result on normal distribution after Box-Cox trans- formation, lognormal distribution, 3-parameter Weibull distribution, largest extreme value distribution, loglogistic distribution, and normal distribution after Johnson transformation. For elapsed time for SC, the task primitive satisfied statistical significance level on normal distribution, normal dis- tribution after Box-Cox transformation, Weibull distribution, 3-parameter Weibull distribution, smallest extreme value distribution, largest extreme value distribution, gamma distribution, logistic distribution, and loglogistic distribution.
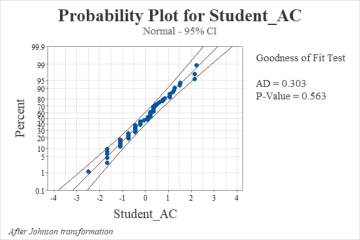
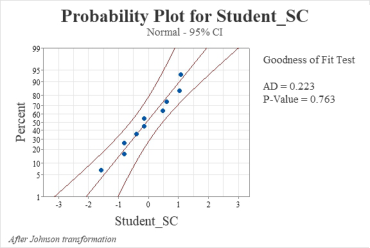
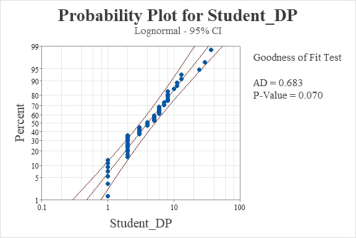
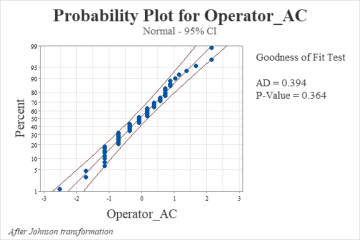
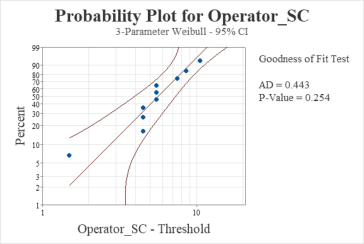
Figures 1–5 summarize the most optimal time distributions represent- ing the highest p-value among time distributions per each task primitive. Figure 1, Figure 2, and Figure 3 include normal distributions (after Johnson transformation) of AC and SC, and lognormal distribution of DP for student
operators’ tasks in the EOP-01 procedure. The average elapsed time from the time distributions are 11.92 seconds for AC, 9.80 seconds for SC, and 6.14 seconds for DP. Figure 4 and Figure 5 show normal distributions (after Johnson transformation) of AC and 3-parameter Weibull distribution of SC for professional operators’ tasks in the EOP procedure, respectively. The aver- age elapsed time from these time distributions are 7.21 seconds for AC and 5.30 seconds for SC.
Figure 1: Normal distribution (after Johnson transformation) of AC for student opera- tors’ tasks in the EOP-01 procedure.Figure 2: Normal distribution (after Johnson transformation) of SC for student opera- tors’ tasks in the EOP-01 procedure.Figure 3: Lognormal distribution of dp for student operators’ tasks in the EOP-01 procedure.
An Investigation of Time Distributions for Task Primitives 27
Figure 4: Normal distribution (after Johnson transformation) of AC for professional operators’ tasks in the EOP-01 procedure.Figure 5: 3-parameter weibull distribution of SC for professional operators’ tasks in the EOP-01 procedure.
CONCLUSION
This study investigated time distributions for five GOMS-HRA task primi- tives from the seven different sets of procedures having different goals and comparing the time distributions depending on participant type. In this paper, time distributions for the five GOMS-HRA task primitives in the EOP-01 procedure are introduced. As a result, several time distributions on the five GOMS-HRA task primitives were found at statistically significant level. Specifically, the greater number of time distributions were found in abnormal operating procedure (AOP)-01, EOP-01 and EOP-02 when compared to the OP procedures. Manipulation-related task primitives, i.e., AC (Performing required physical actions on the control boards) and SC (Selecting or setting a value on the control boards), satisfied relatively many statistical distributions with high confidence levels in comparison with other task primitives.
A relatively smaller number of time distributions satisfied statistically significant levels in the OP procedures. Actually, some tasks in the OP pro- cedures include elapsed time for plant parameters to reach certain values. These may make it difficult to get time distributions with statistical signifi- cance level. Also, no time distributions have been found on RC (Obtaining required information on the control boards) regardless of participant type. In the SHEEP experiment, each participant carried out six scenarios at one setting. Accordingly, there may be learning effects for participants to obtain
any information from the Rancor interface. The learning effect may interfere with satisfying time distributions.
Our research team continues analyzing the experimental data. Further analyses will be performed to clarify these issues and arrive at better time distributions applicable to dynamic HRA in the future. Already, these data show the possibility of using GOMS-HRA task level primitives to arrive at time distributions. Such time distributions may eventually prove as useful as outright HEP estimations in future HRA applications.
ACKNOWLEDGMENT
This study was supported by an INL-funded project, Standard Research Con- tract 280761. Chosun University acknowledges funding received from INL to support this research. INL is a multi-program laboratory operated by Battelle Energy Alliance LLC for the U.S. Department of Energy under con- tract No. DE-AC07-05ID14517. and supported by the National Research Foundation of Korea (NRF) grant funded by the Korea government (MSIT) (No. RS-2022-00144172).
REFERENCES
Boring, R. & Rasmussen, M., (2016). GOMS-HRA: A method for treating subtasks in dynamic human reliability analysis. Proceedings of the European Safety and Reliability Conference, pp. 956–963. Boring, R. et al., (2022). Software Implementation and Demonstration of the Human
Unimodel for Nuclear Technology to Enhance Reliability (HUNTER), INL/RPT- 22-66564, Idaho National Laboratory. Park, J. et al., (2022). A framework to collect human reliability analysis data for nuclear power plants using a simplified simulator and student operators. Reliability Engineering & System Safety, vol. 221, p. 108326. Park, J. et al., (2023). Analysis of human performance differences between students
and operators when using the Rancor Microworld simulator. Annals of Nuclear Energy, vol. 180, p. 109502. Swain, A. & Guttmann, H., (1983). Handbook of human-reliability analysis with emphasis on nuclear power plant applications, NUREG/CR-1278, Sandia National Laboratory, Albuquerque, NM, USA.
LISTED IN THE AHFE DIGITAL BOOKSTORE CATALOGUE
Explore the complete digital volume
Emerging Technologies and Future of Work
Read this individual research paper free through the original publisher, or explore the full digital proceedings book.
ISBN 978-1-958651-93-3
Explore this ISBN in the AHFE Bookstore ↗Listed in the July 2026 bookstore catalogue; search by ISBN to confirm current availability · Digital book purchase optional